Training Data for Robot Learning and Manipulation

We collect and structure manipulation datasets for robotic systems — covering human demonstrations, robot arms, real-world environments, and synthetic scenarios.

Explore sample data View cases
Image
Full-Stack Robotics Vendor: From capture to labeled dataset
Capture Equipment: Sensors & robot hardware, synchronized in real time
Data Collection from: Robotic arms, custom hardware & prototypes

Robotics Data Services

Image

Data Collection

Robot training data collected via teleoperation & kinesthetic demonstrations on your equipment: robot arms, prototypes & custom hardware.
Image

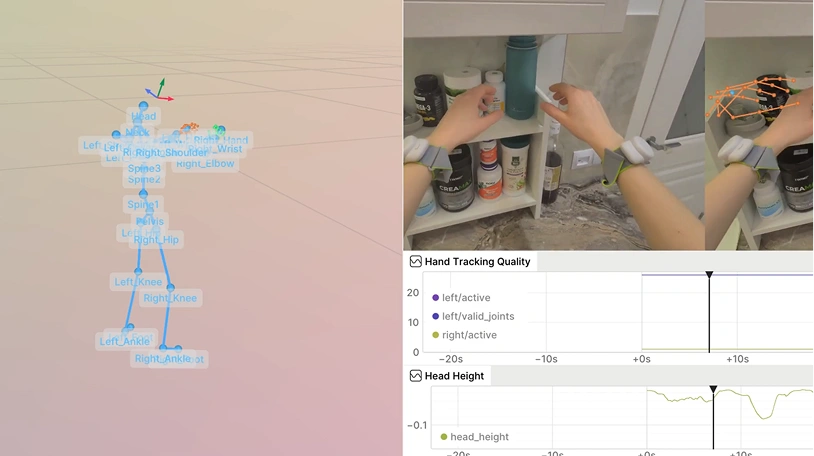
Egocentric Video Data Collection

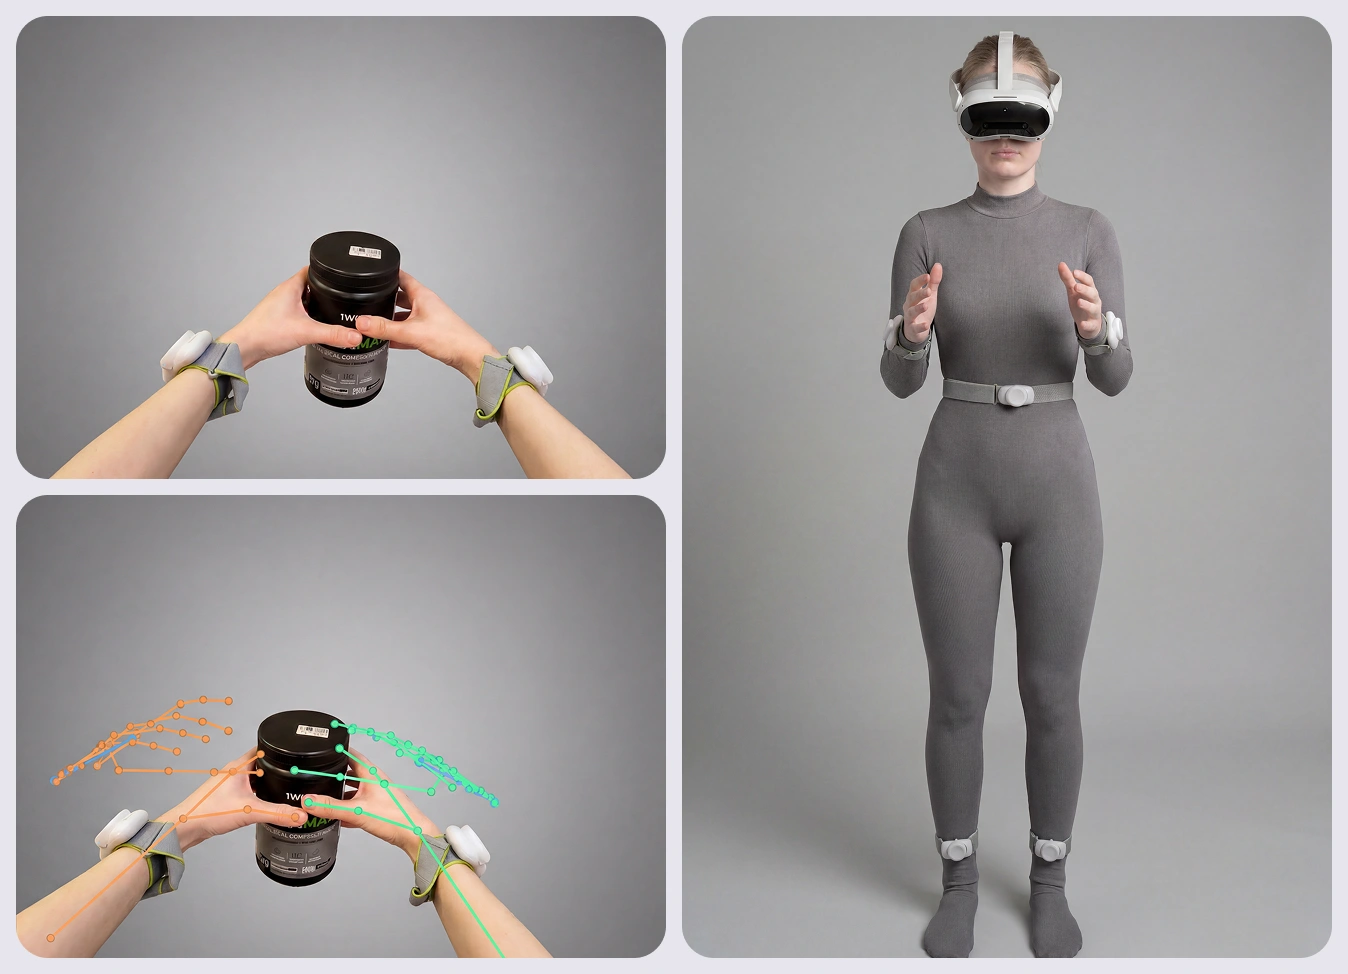
First-person capture: stereo RGB, depth, 6DoF motion, full-body skeleton. 15K+ scenarios, 200 hours.
Image

Support

Continuous dataset support including validation, data cleaning, and structured review cycles.
Image

Data Annotation

Frame-level labeling of manipulation episodes: object pose & grasp points, trajectories, keypoints & hand pose, plus scene, action & object labels at every timestep.

Robotics Data Capture Equipment

01

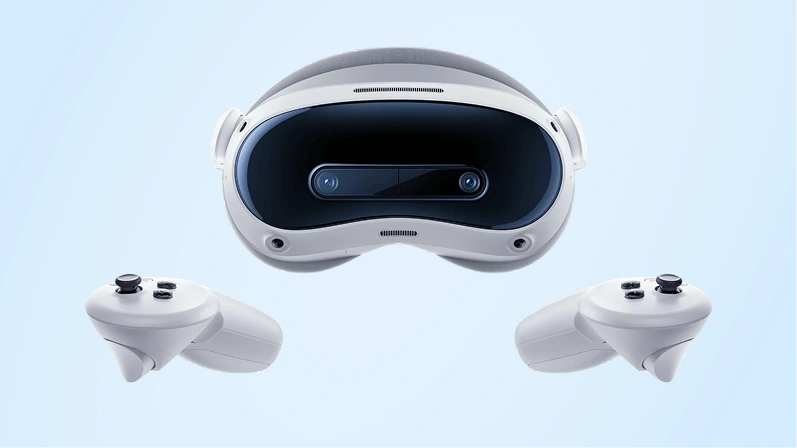
Head-Mounted

Pico 4 Ultra

Image
02

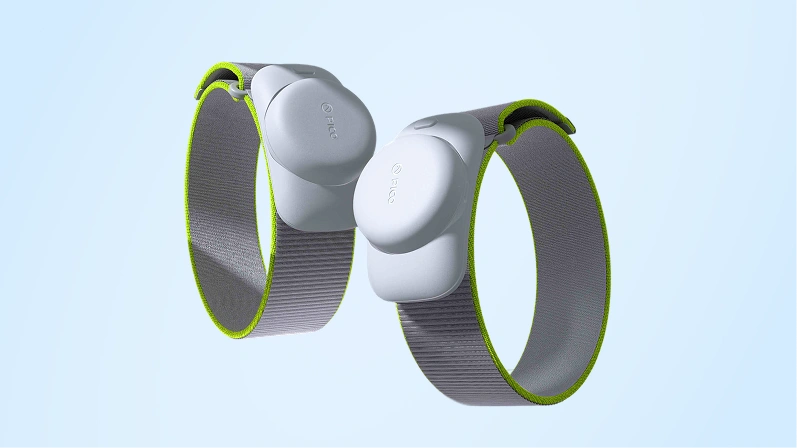
Body Tracking

Motion Trackers

Image
03

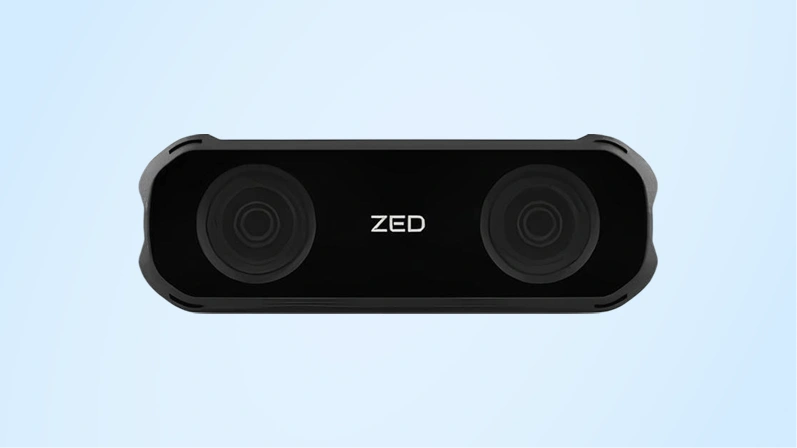
Depth / RGB

ZED Stereo Cameras

Image
04

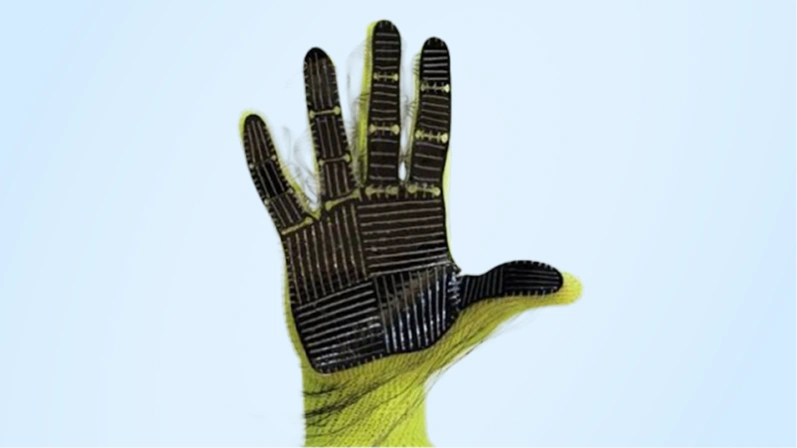
Hands & Contact

Tactile Gloves

Image
05

Robot Hardware

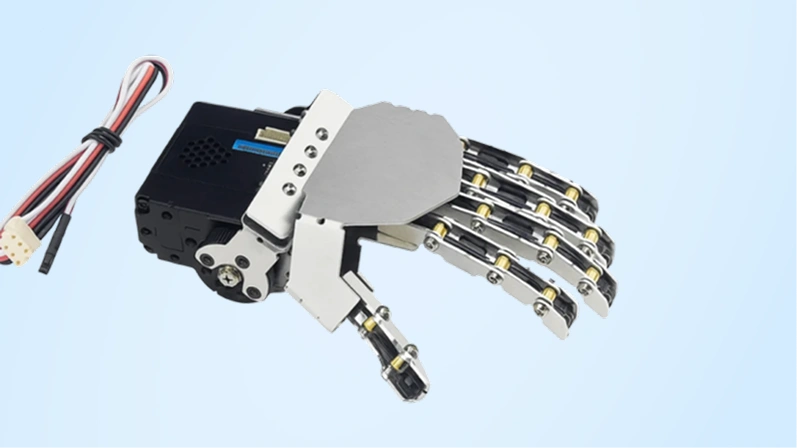
Grippers & Robot Arms

Image
Image

Need Proof?

See the results we’ve delivered for leading tech companies and startups

Explore our cases

Robot Data Collection Methods

Teleoperation Capture

Human operators control robot hardware remotely via VR controllers, space mice or exoskeleton rigs while synchronized sensor streams & operator actions are recorded. Produces demonstration data with action labels, directly usable for imitation learning & behavior cloning.

Kinesthetic Teaching & Physical Demonstration

A human physically guides the robot through a task while joint states, end-effector pose & force-torque data are logged alongside camera streams. Ideal for contact-rich manipulation tasks requiring natural motion priors.

Autonomous Robot Operation Logging

Instrumented robots execute tasks in controlled or real-world environments while all onboard sensor streams are recorded, filtered & timestamped. Policy rollouts, including failures & human interventions, are kept for annotation & evaluation.

Human Motion Capture & Retargeting

Human participants perform target tasks wearing MoCap suits or marker arrays. Captured motion is retargeted to robot morphology for training locomotion & manipulation policies.

Simulation & Synthetic Generation

Robotic scenarios are replicated in physics simulators with domain randomization across textures, lighting, object geometry & sensor noise, generating large-scale data with automatic ground-truth labels.

Multi-Modal Field Deployment

Sensor-equipped robots or human operators are deployed in target environments such as warehouses, hospitals, construction sites & outdoor terrain to collect in-distribution data at scale.

Robot Training Data by Source

Human Demonstration Data

Human Demonstration Data

People performing structured tasks, recorded with hand pose, object interaction & first-person video. Annotated for motion, intent & task phase.

Use cases

  • Imitation learning for dexterous manipulation
  • Hand pose & grasp estimation
  • Action recognition & task segmentation
01
Image

Humanoid Robot Data

Recordings from humanoids operating alongside people, covering whole-body motion, proximity responses, handoffs & collaborative tasks in shared spaces.

Use cases

  • Whole-body control & locomotion policies
  • Human-robot handover
  • Human-aware motion in shared spaces
02
Image

Robot Arm Data

Manipulation episodes from single & dual-arm setups, with joint states, end-effector pose, force-torque & synchronized RGB video at each timestep.

Use cases

  • Pick-and-place & assembly policies
  • VLA training & fine-tuning
  • Contact-rich manipulation with force-torque feedback
03
Mobile and Service Robot Data

Mobile and Service Robot Data

Logs from mobile, service & warehouse robots in real-world scenarios, with odometry & camera streams structured for navigation & task execution.

Use cases

  • Indoor navigation & mapping (SLAM)
  • Mobile manipulation in warehouses
  • Obstacle avoidance in dynamic environments
04
Robot Courier Data

Robot Courier Data

Delivery robot runs indoors & outdoors, covering route execution, parcel handoff & pedestrian interaction in urban environments.

Use cases

  • Outdoor & sidewalk navigation
  • Social navigation among pedestrians
  • Long-horizon route following
05
Synthetic Data

Custom Hardware & Prototypes

Data recorded on early-stage or proprietary devices. We adapt the capture rig to your sensor layout & record directly in your robot's action space.

Use cases

  • Policy training on your own embodiment
  • Cold-start data for new hardware
  • Policy evaluation before deployment
06

Need Data from Your Own Robots?

Send us your robot arms, humanoid systems or custom devices. We'll scope & collect the robot training data you need. All data collected on your equipment belongs to you and stays under NDA.

Image

How to make a good dataset

An effective dataset for robot learning captures:

  • Robot embodiment: actuation, sensor data, and physical configuration
  • Environment: layout, external agents, and operational context
  • Tasks and events: goals, constraints, and conditions in real-world scenarios
Datasets structured around these dimensions give models the signal they need to perform across manipulation tasks, dynamic environments, and real-world applications.
Robotics Data

Environment

  • Layout
  • Agents

Tasks & Events

  • Goals
  • Constraints

Robot Embodiment

  • Sensors
  • Actuation

Similar Dataset

robot dataset

Lerobot SO-101 Manipulations Dataset

Lerobot SO-101 dataset is a compact, high-quality set of 20 teleoperated robotic arm recordings (~30 FPS) captured on the calibrated […]

Tasks
Pick-and-place, manipulation
Format
LeRobot v2.1 (Parquet + MP4)
Sensor data
3 camera views, 7-axis state and action space
Episodes
20
Training
Compatible with imitation learning pipelines
robotic dataset

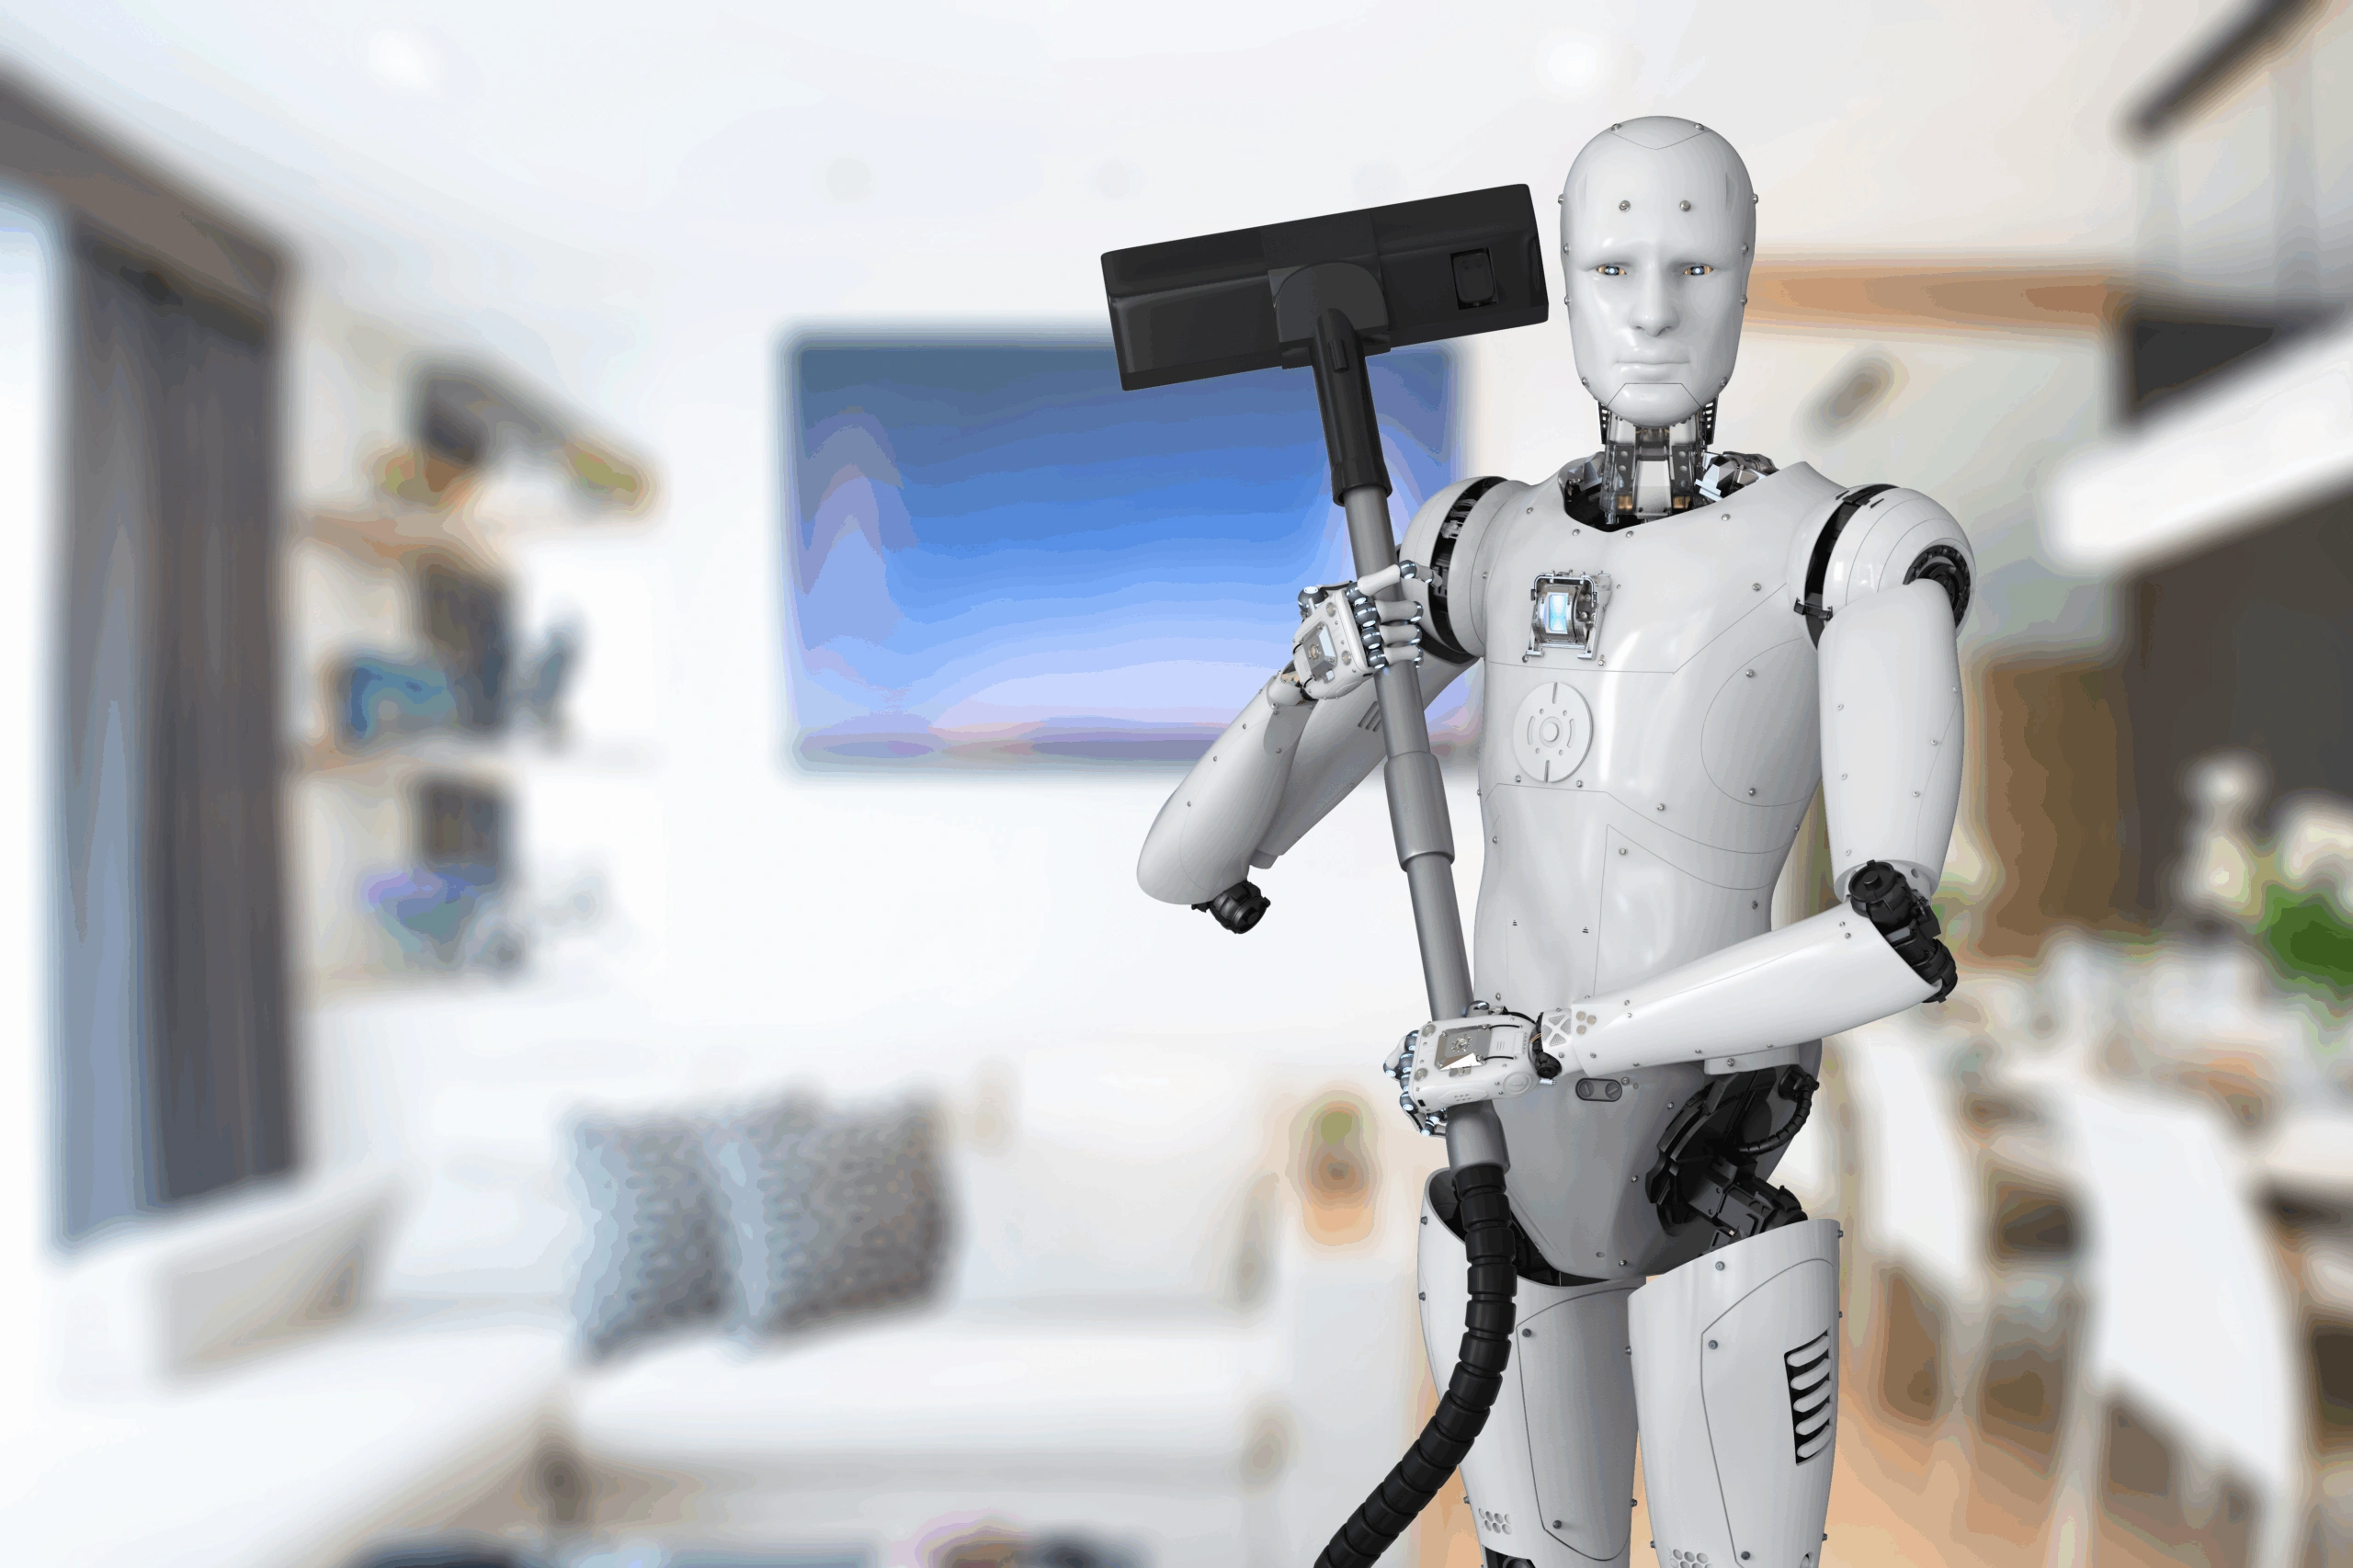
Robotic Household Activities Dataset

This droid dataset includes recordings of cleaning, laundry folding, dishwashing activities, combining head-mounted video with detailed robotic data streams from […]

Tasks
Human Activity Recognition, motion analysis, action segmentation
Sensor data
3-axis accelerometer, gyroscope, magnetometer + orientation quaternions
Video
Head-mounted MP4, JSON metadata
Hours
1,000
Use
Robotic learning, foundation models, humanoid systems

Why Robot Training Data Is Hard to Get

Challenge

Public robotics datasets are often task-specific, limiting model training variety
Lab-collected datasets may not cover conditions your robot encounters in deployment
When no suitable dataset exists, building one takes significant time and resources
Combining datasets from multiple sources creates inconsistent training pipelines

How Unidata helps

We provide diverse datasets across manipulation tasks, human demonstrations & robot types
We source data collected in operational environments, warehouses, and human-shared spaces
We handle custom data collection, from human demonstrations to robot arms
Our datasets follow consistent structure, ready for model training and robotic learning

Robotics Training Data by Industry

Image

Medicine and Healthcare

Surgical robots, rehabilitation systems, and assistive devices.

Image

E-commerce and Retail

Warehouse robots, picking systems, and delivery automation.

Image

Smart Agriculture

Field robots and autonomous farming equipment.

Image

Automotive Systems

Autonomous vehicles and roadside robotic systems.

Image

Urban Management

City logistics robots and traffic monitoring systems.

Image

Real Estate and Construction

Robots for property scanning, mapping, and digitization.

Image

Mining and Oil & Gas Industry

Industrial robots operating in complex and confined environments.

Image

Public Security

Patrol robots and anomaly detection systems.

Image

Logistics and Last-Mile Delivery

Courier robots operating indoors and outdoors.

Image

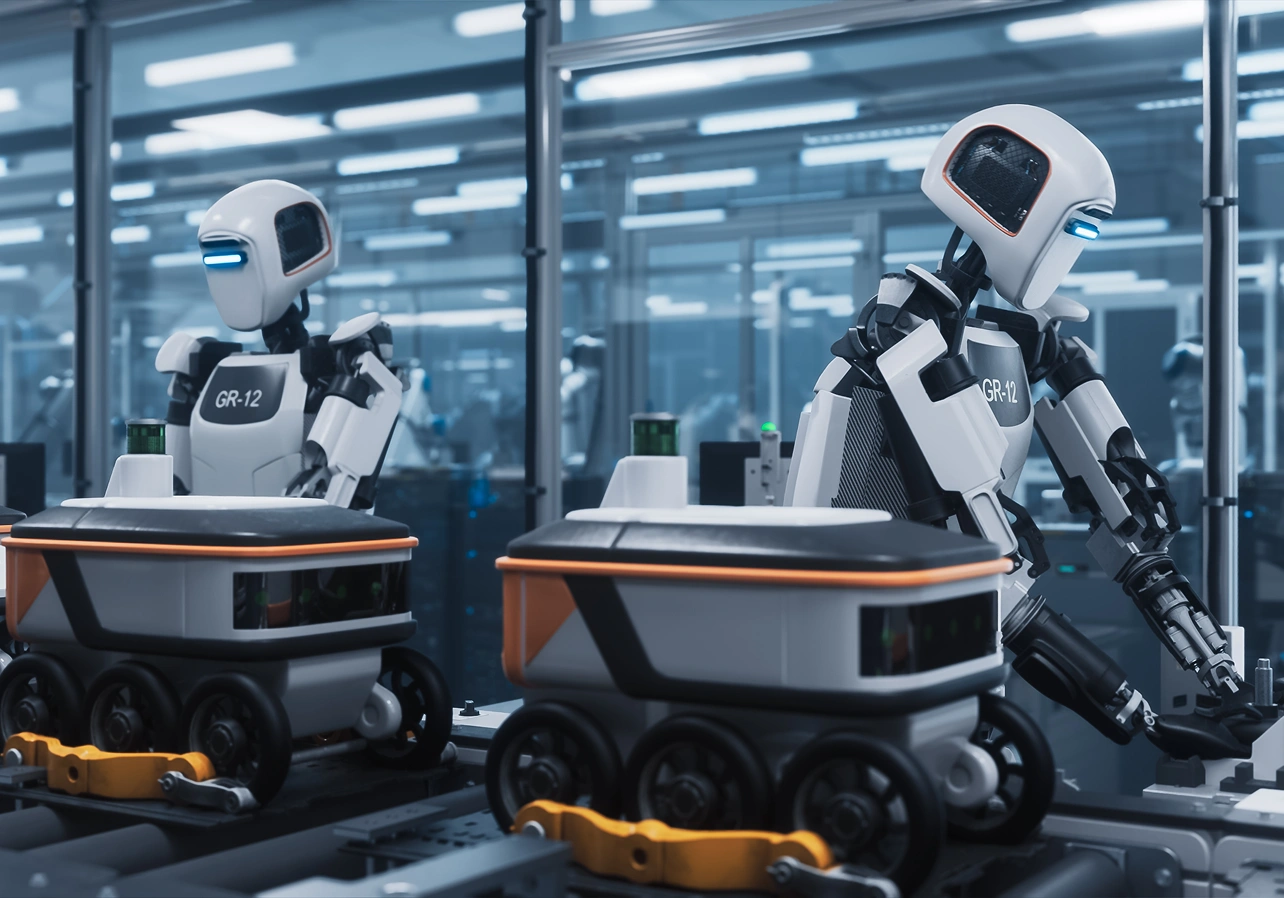
Manufacturing and Assembly

Robot arms and automated production systems.

Image

Food and Hospitality

Robots for food preparation and kitchen delivery.

Need Proof?

See the results we've delivered for leading tech companies and startups

Explore our case

What is Robotics Data?

Robotics data is time-synchronized, structured information collected from robots, sensors, and human-operated systems. It is used to train models, test robotic learning methods, and improve model performance on manipulation tasks across real-world applications.

This data allows robotic systems to:

  • Recognize and track different objects across diverse robotic environments
  • Plan and adjust motion in response to dynamic environments and changing physical conditions
  • Manipulate objects across varied tasks, supporting model training for robot arms and humanoid robots

Datasets that combine sensor data, RGB inputs, and human demonstrations give models trained on robotic manipulation more signal per episode, reducing the volume of data collected needed for stable robotic learning.

Cases

How It Works: Our Process

A Clear, Controlled Workflow From Brief to Delivery

01 Briefing & Scope
Together
Share your robot embodiment, target tasks & training format. We match you to an existing dataset or scope a custom collection
02 Sample or Pilot
Together
Review sample manipulation episodes from our catalog or a pilot batch recorded on your robot arm, humanoid or custom hardware
03 Agreement & NDA
You
Sign off on scope, episode volume, timeline & pricing. All data collected on your equipment belongs to you
04 Data Preparation
Unidata
Teleoperation, kinesthetic demos or egocentric capture, followed by annotation of grasps, trajectories & object pose
05 Quality Control
Unidata
Sensor sync checks, calibration review & episode validation against the agreed spec
06 Delivery & Handoff
Together
Episodes
07 Ongoing Support
Unidata
Re-collection for new tasks, environments or robot configurations as your model evolves

FAQ

What data is needed to train a robot arm for grasping and manipulation?
Effective training data for robot arm grasping includes RGB video, depth inputs, gripper state logs, and sensor data from multiple grasp attempts across different objects. Human demonstrations of grasping and placement help models generalize across object shapes and sizes.
What is the difference between robotic manipulation data and general robotics data?
Robotic manipulation data captures robot interactions with different objects — grasping, placing, assembling. General robotics data includes navigation, sensor data, and environment interaction. Most models trained for manipulation require both.
How does synthetic data supplement physical data collection?
Synthetic robotics data is generated in simulation to cover scenarios that are dangerous, rare, or too costly to reproduce physically. It works best when combined with data collected from real robots to reduce the simulation-to-real gap.
Can you collect training data from our own robotic systems?
Yes. We work with your robot arms, mobile robots, and human-operated equipment. Custom data collection is scoped based on your hardware, tasks, and dataset size requirements.
How is robotics training data different from computer vision datasets?
Computer vision datasets typically contain static images or video clips. Robotics training data is time-synchronized and multi-modal — combining RGB video, sensor data, joint states, and action labels captured sequentially across manipulation tasks. This makes robotic data collection, annotation, and model training significantly more complex.

Why Companies Trust Unidata’s Services for ML/AI

Share your project requirements, we handle the rest. Every service is tailored, executed, and compliance-ready, so you can focus on strategy and growth, not operations.

Rely on 1,100+ Experts

  • 1,100+ in-house labelers and specialists
  • Consistent quality and rapid scaling
  • Complex multi-type annotation projects
01

Discover 19+ Industry Expertise

  • Finance, IT, E-commerce, Retail, Healthcare, Medical, Fintech, and more
  • Deep domain knowledge for industry-specific requirements
  • Support for industry-specific annotation challenges
02

Get Turnkey Services for ML/AI

  • From data collection to labeling and validation
  • Project tailored to your requirements
  • Complex annotation, multiple annotation types at once
03

Ensure Legal & Secure Data

  • GDPR & CCPA compliant
  • AWS ISO 27001/27701 storage
  • Curated and legally sourced
04

Process Different Content Types

  • Multimodal Data: 333K+ texts, 550K+ audio, 11K+ videos, 26K+ images
  • Formats: DICOM, LiDAR, and specialized types
  • Annotation: multiple types at once with high accuracy
05

Request Custom Research

Have questions about the process? Every project starts with a free consultation — no commitment required.

Explore our cases

What our clients are saying

Tyler Rand

Airship AI

“We were very happy with the quality of the data that we purchased. It will assist our efforts to improve our product. The team at Unidata was very responsive to our needs, and provided the data format needed to complete our tasks. We are happy to state that Unidata delivers a high quality product in an effective and efficient manner.”

D. B.

IdentifAI Labs

“We partnered with Unidata for a vast collection of webcam and smartphone assets and were very satisfied. The data quality was excellent, maintaining high resolution and clarity across all formats to meet our specific technical needs. The procurement process was seamless thanks to their customer service. The team was proactive and transparent, ensuring smooth communication from start to finish. Although the investment was significant, the professional caliber of the data and the reliability of the service made it a worthwhile value.”

ChunXiao Liu

DFRobot

“We purchased a dataset of 50,000 license plates from around the world, and the trained model performs very well.”

Trusted by the market's leading brands

logo-identifai logo-unissey Logo Partners logo-etuitus

Ready to get started?

Tell us what you need — we’ll reply within 24h with a free estimate

    Andrew
    Head of Client Success

    — I'll guide you through every step, from your first
    message to full project delivery

    Thank you for your
    message

    It has been successfully sent!

    We use cookies to enhance your experience, personalize content, ads, and analyze traffic. By clicking 'Accept All', you agree to our Cookie Policy.